Research Notes
Records Before They Became Products
From motion control to inspection UI — things we built and tested ourselves. The structures worked out here led to what is now AimFactoryCore.
 NOTE 09
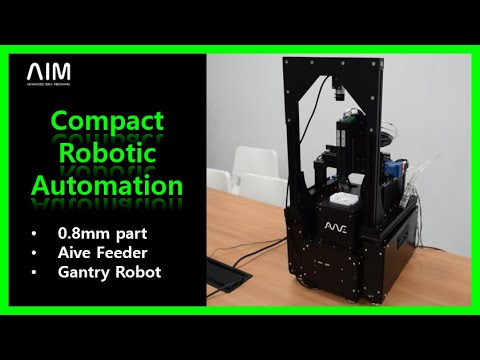
Integrated vision · feeder · robot control software
Working with motor/mechanism specialist Techno Hands, we tied everything from vision to robot motion into one piece of software.
- Elmo motion control
- UDP axis control
- Block-build robot program
 NOTE 08
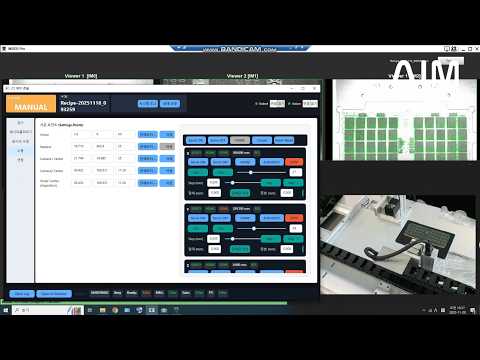
IAI Cartesian robot + XSEL — 2-camera precision inspection cell
From rough coordinates to precise corner coordinates with two cameras — inspection-position moves automated.
- IAI Cartesian robot
- XSEL controller
- TCP control
 NOTE 07
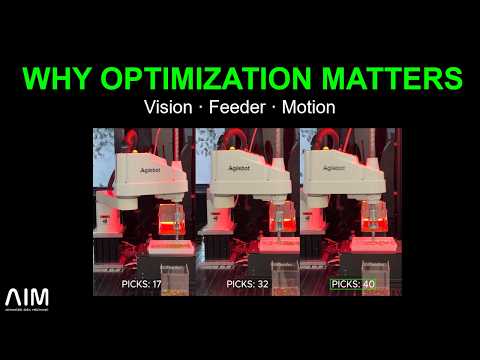
Motion blending and six vision coordinates — pick and place cycle comparison
We ran three operating methods side by side under the same conditions. Pick and place speed is not determined by the robot's maximum speed alone.
- Robot motion blending
- Up to six picks per capture
- Feeder · vision · motion optimized together
 NOTE 06
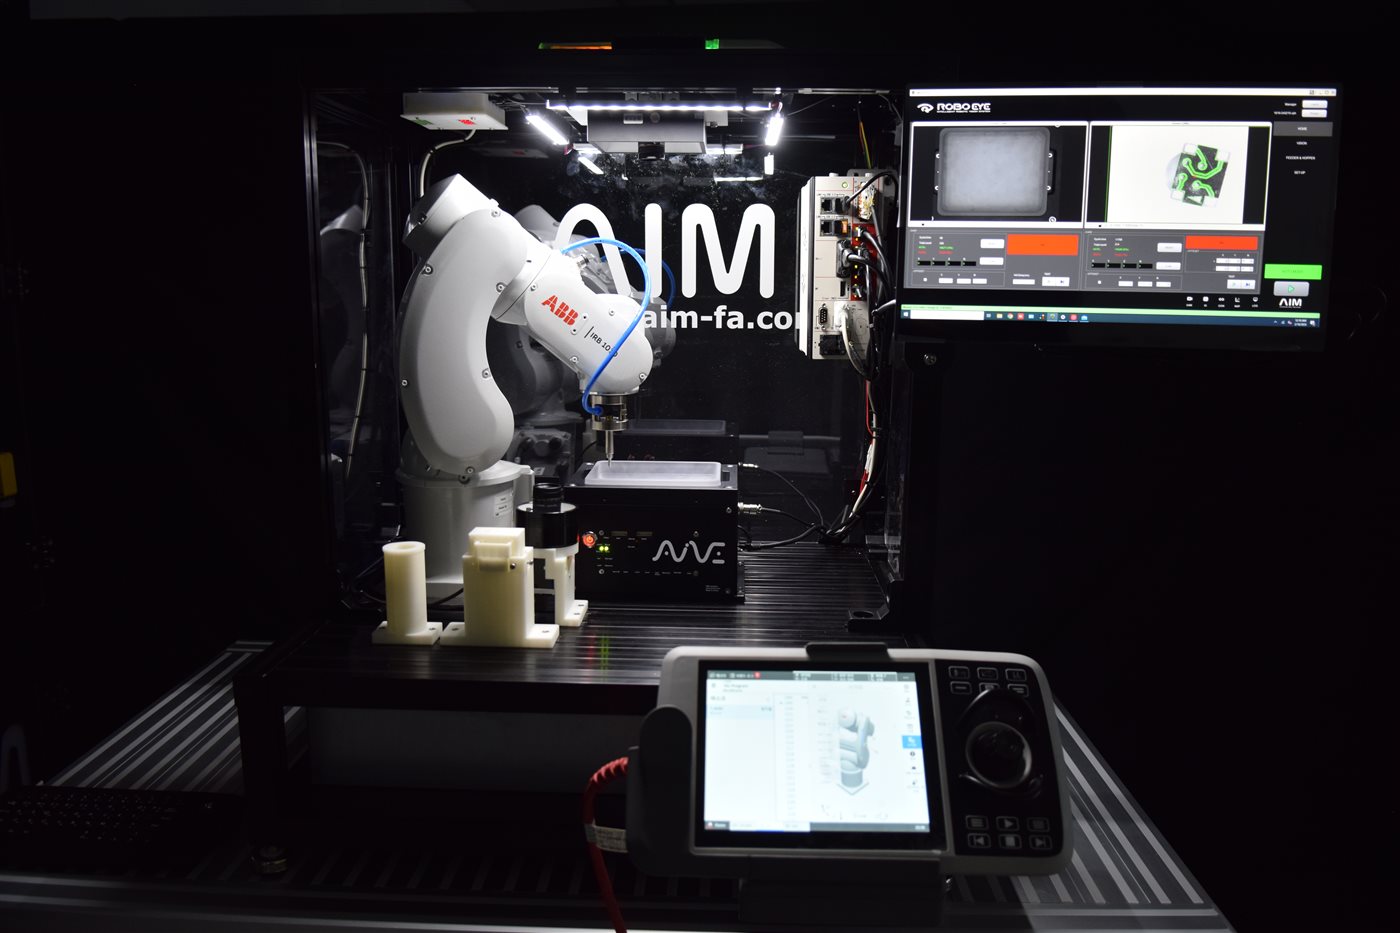
ABB robot integration — AimFactoryCore plug-in
Verified the TCP/IP communication structure between the ABB IRC5 controller and AimFactoryCore.
- ABB IRC5
- RAPID communication
- TCP/IP socket
 NOTE 05
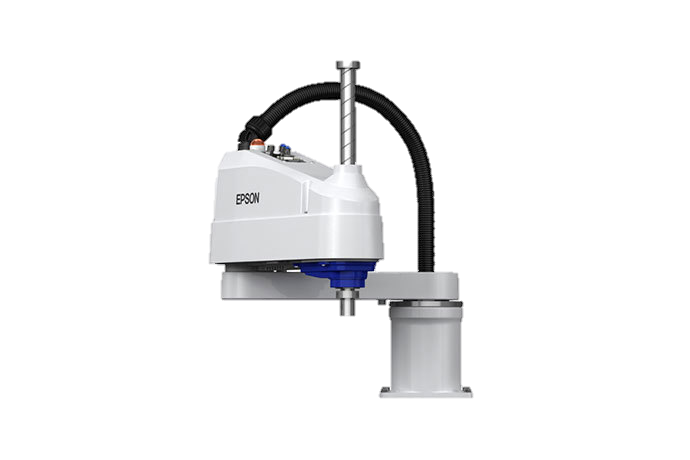
EPSON robot integration — RC+ plug-in
A plug-in that reduces RC+'s complex TCP/IP communication to a single line: Call AIVEManual(mm,hz,sec).
- EPSON RC90
- RC+ SPEL+
- TCP/IP Port 201
 NOTE 04
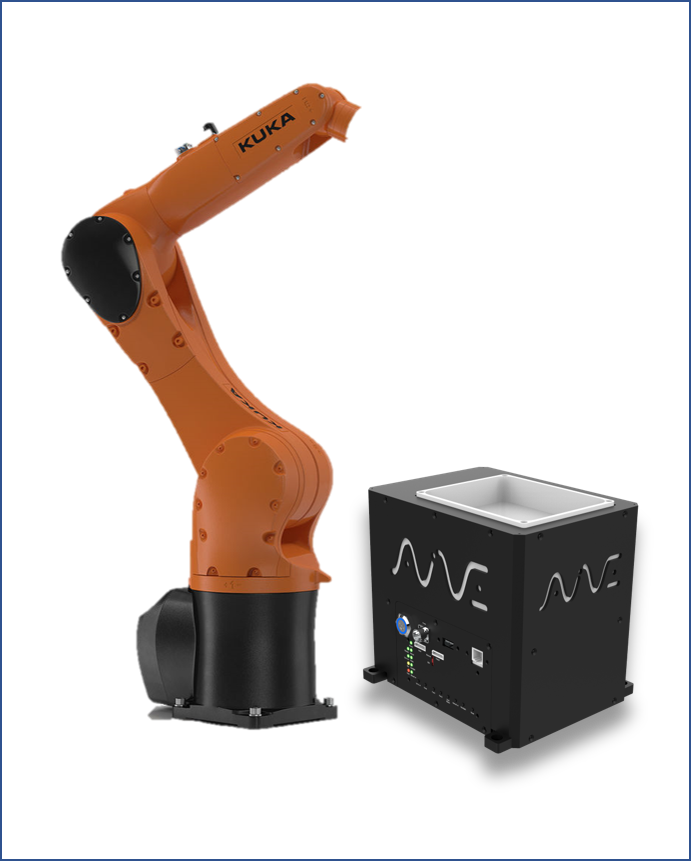
KUKA robot integration — Ethernet KRL plug-in
Verified controlling AIVE directly via KUKA's EthernetKRL XML configuration and EKI_Send.
- KUKA KRC4
- KRL
- EthernetKRL
 NOTE 03
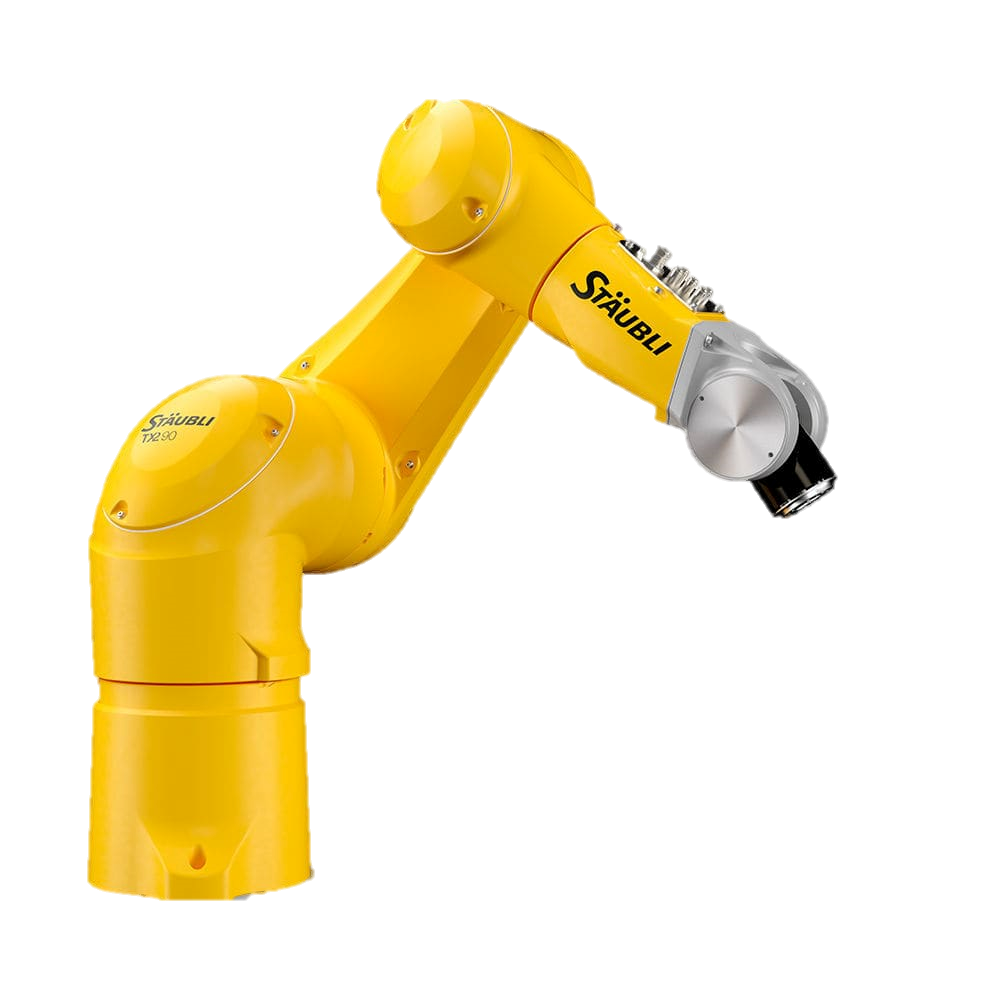
Stäubli robot integration — VAL3 TCP socket plug-in
Wrapped VAL3 socket communication in a call AiveManual() function to control AIVE and RoboEye from Stäubli.
- Stäubli SP2
- VAL3
- TCP Clients socket
 NOTE 02
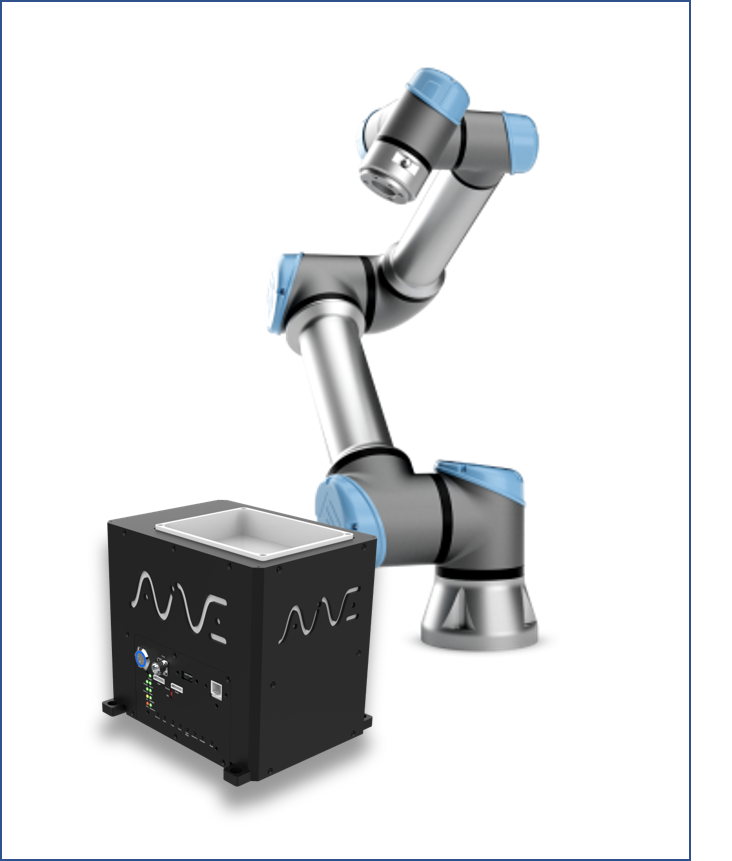
Universal Robots integration — URCaps plug-in
Connect up to four AIVE units simultaneously via PolyScope URCaps, and handle vision height offset inside the UI.
- Universal Robots
- URCaps
- PolyScope
 NOTE 01
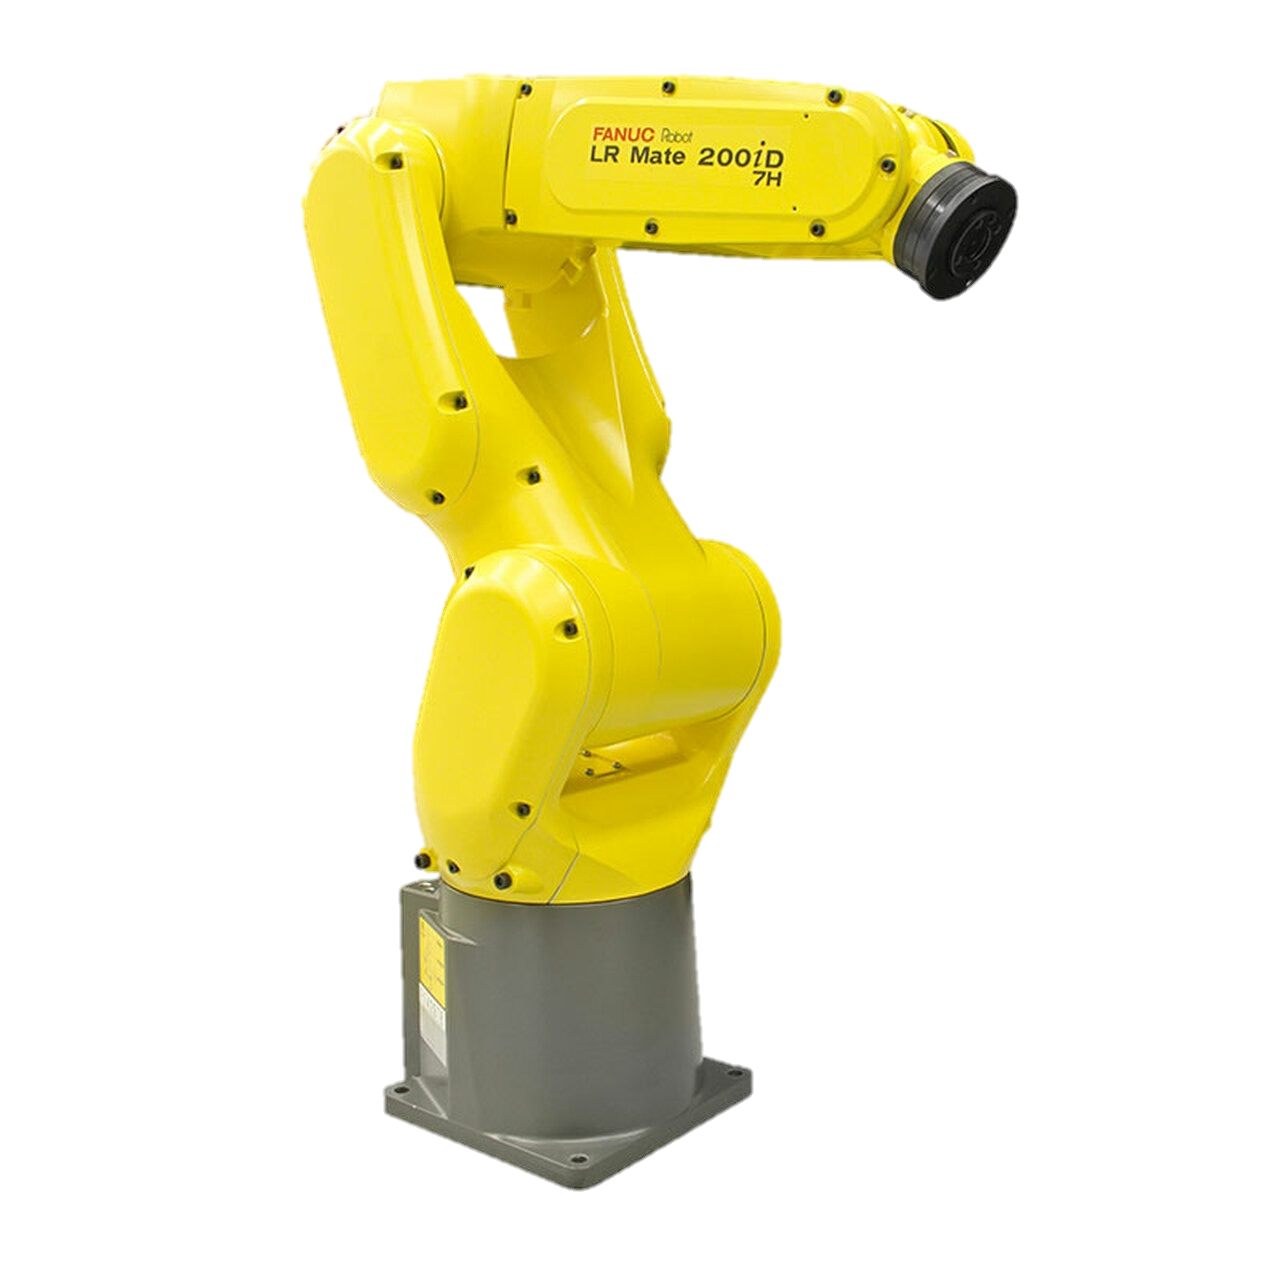
FANUC integration — early KAREL-based model
An early plug-in structure wrapping AIVE TCP communication in FANUC KAREL. It became the basis of today's AimFactoryCore FANUC integration.
- FANUC KAREL
- Call AIVEReady()
- Call AIVEManual(mm,hz,sec)
This technology is inside our products today
The structures validated in research notes are now part of AimFactoryCore and Robot Suite.