ROBOT INTEGRATION
Integrated industrial robot vision setup — robot, vision and feeder in one flow
The robot setup and integration an SI or robot engineer used to do separately is bundled with vision and feeder into one setup. Most robots receive the pick coordinates from us; for two robots — Hyundai Robotics and Agilebot — we handle the robot program itself from our screen.

Dedicated integration — Hyundai Robotics · Agilebot
IO · Modbus · TCP standard communication
Recipe = vision + robot + feeder
Vision, robot and feeder operated together
WHY
Why integrated setup
Until now, automation cells were built with vision, robot and feeder apart — each set up separately by a different specialist. The result is a cell that only works on good parts and is hard to add models to. AIM ties vision, robot and feeder into one flow from the setup stage.
-
Less SI burden
No separate robot expert needed
Standard integration for many robots · dedicated integration for two (Hyundai Robotics, Agilebot) — the cell interface does not have to be redesigned when a new robot comes in.
-
Repeatability
Coordinate alignment you check on screen
At the calibration result step, the average, minimum and maximum error appear in mm. Whoever sets it up checks it by the same procedure.
-
Scalability
Add models with a Recipe
The cell is not rebuilt when a model is added. Vision, robot and feeder are bundled in one Recipe and operated together.
CONTRAST
Conventional approach vs AIM integration
For the same automation cell, the setup approach makes a large difference to the deployment schedule and operating stability.
| Item | Conventional | AIM integrated setup |
|---|---|---|
| Robot setup | Done separately by an SI / robot engineer | AIM bundles it with vision in one setup |
| Coordinate alignment | Manual correction · depends on the operator | Calibration error checked on screen in mm |
| Communication | IO/TCP redesigned for every project | AimFactoryCore absorbs it through a standard interface |
| Adding a model | Vision, robot and PLC all modified separately | One Recipe switches vision, robot and feeder at once |
| Operating screen | Separate vision/robot screens, operator learning burden | Operated from one screen — vision, robot and feeder integrated |
FLOW
Integrated setup in 4 steps
From checking the part conditions to registering the Recipe — one person sets up vision, robot and feeder in one flow.
- 1
Understand the part and cell conditions
Part shape, material, volume and robot model are confirmed together to define the setup scope.
- 2
Align vision and robot coordinates
The calibration workflow converts image coordinates into robot coordinates. 9-pose samples with residual verification.
- 3
Connect the robot interface
AimFactoryCore standardizes the robot/PLC protocol. Signals, triggers and sequences are defined in one place.
- 4
Register the Recipe and verify operation
Per-model vision conditions, robot paths and feeder patterns are bundled in a Recipe; model changeover and repeatability are checked.
See the full deployment procedure (part review → production stabilization) →
BRANDS
Robot and PLC brands through a standard interface
When a new robot brand comes in, the cell interface does not have to be rewritten. AimFactoryCore standardizes the communication and absorbs it.
- ABB
- FANUC
- KUKA
- Yaskawa
- Mitsubishi
- Hyundai
- Doosan
- Universal Robots
- TM Robot (Techman)
- Hanwha
- Rainbow
- Omron
- Denso
- Stäubli
- Kawasaki
- Nachi
- Epson
- Comau
- Yamaha
- JAKA
* The list above shows representative examples; additional brands can be supported on a per-project basis.
SIGNALS
Who gets which signal — at a glance
AimFactoryCore organizes the signal flow between robot, PLC, vision and feeder in one place. From the floor, you only need to see "what goes from where to where."
- 01 Vision Robot
Sends pick coordinates and triggers (TCP/IP or IO). The coordinates are already converted into robot coordinates, so the robot needs no separate correction.
- 02 PLC Line
Shares sequences, interlocks and safety. AimFactoryCore organizes the signals before handing them to the PLC, so the PLC logic stays simple.
- 03 Vision Feeder
Vision controls the vibration and rotation patterns directly. Hopper and lighting synchronization are handled in the same place.
- 04 AimFactoryCore Everything
One Recipe switches HMI → PLC → Robot → Vision → Feeder at the same time. The operator only selects the model name.
Protocol and interface structure (in depth) — RoboInterface →
4-layer platform integration structure (in depth) — integrated platform →
RELATED
Related resources
SOLUTION
Multi-model operation (Recipe)
One Recipe changes the model — so operation does not stop.
Learn more →
GUIDE
Getting started
Part review → POC → cell setup → production stabilization, in 4 phases.
Learn more →
TECHNOLOGY
Calibration technology
A calibration workflow where the average, minimum and maximum error are checked on screen in mm.
Learn more →
PRODUCT
Hyundai Robotics models and catalogue
HH4·HH4E·HH7·HH7E·HH8 specifications, catalogue, CAD and the integrated operating UI.
Learn more →
Cases applied on real lines
Semiconductor Destructive Inspection Automation That Finds Inspection Points Without Fixed Coordinates
Semiconductor · Electronic component manufacturing · Undisclosed
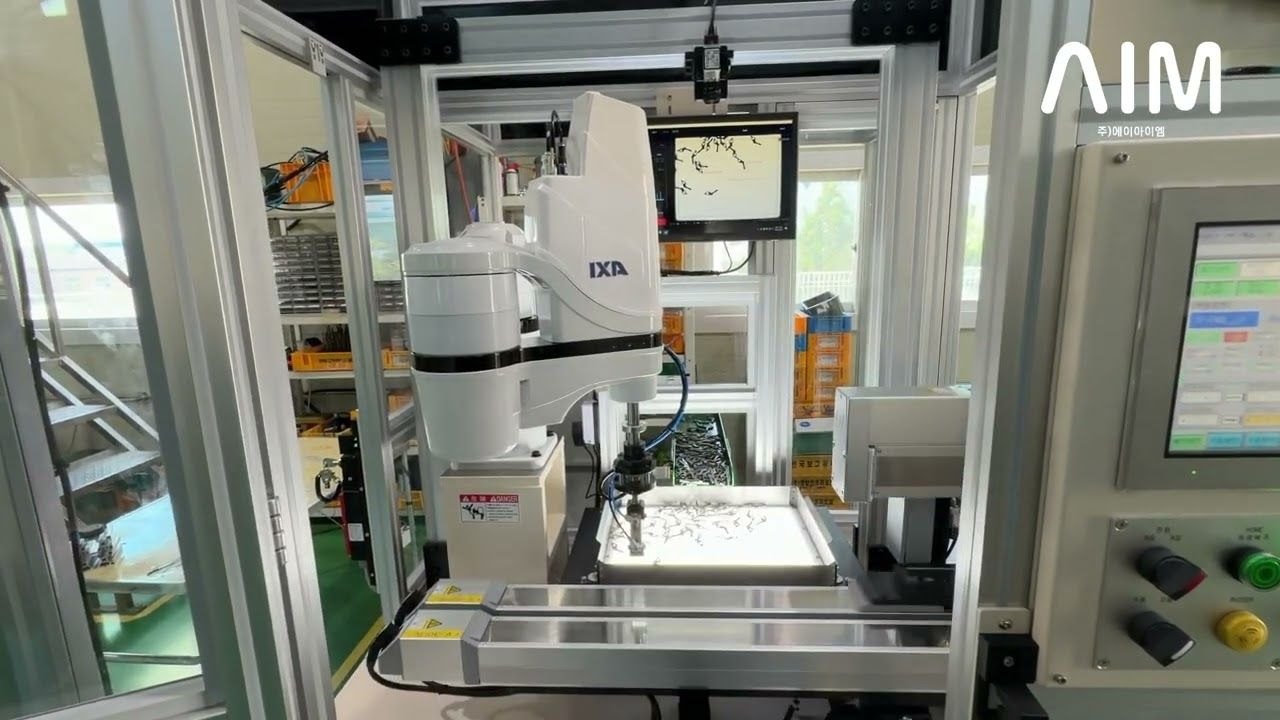
High-Mix Injection-Molded Parts Picked and Placed at a ~2-Second Cycle Time
Plastic injection molding · Undisclosed
Zipper Insertion That Never Waits for Alignment — Left/Right Recognition Switches the Insertion Motion Automatically
Apparel accessories · Undisclosed
START
We will review the robot setup and integration with you.
Tell us the robot and PLC you use today and your part conditions, and we will review the integrated-setup feasibility and schedule together.