
Case Study · Plastic injection molding · Electronic components

High-Speed Feeding of Plastic Injection-Molded Parts — One Part Every ~2 Seconds with a Cartesian Robot

The UNI FEEDER flexible feeder, RoboEye machine vision and a Cartesian robot were combined to recognize the position and orientation of plastic injection-molded parts in real time and pick and place them at high speed with a cycle time of about 2 seconds.

Pick-and-place cycle time per injection-molded part Based on the plastic injection-molded parts shown in the video.
~2 s

Plastic Injection-Molded Part Auto-Feeding | Cartesian Robot × UNI Flexible Feeder High-Speed Pick & Place

Watch on YouTube →

What and how

Configuration of this case

Part
Plastic injection-molded parts (various shapes)
Process
Flexible feeder → real-time position and orientation recognition → Cartesian robot high-speed pick-and-place
Robot
Cartesian robot
Feeder · Vision
UNI FEEDER + RoboEye machine vision
Industry
Plastic injection molding · Electronic components
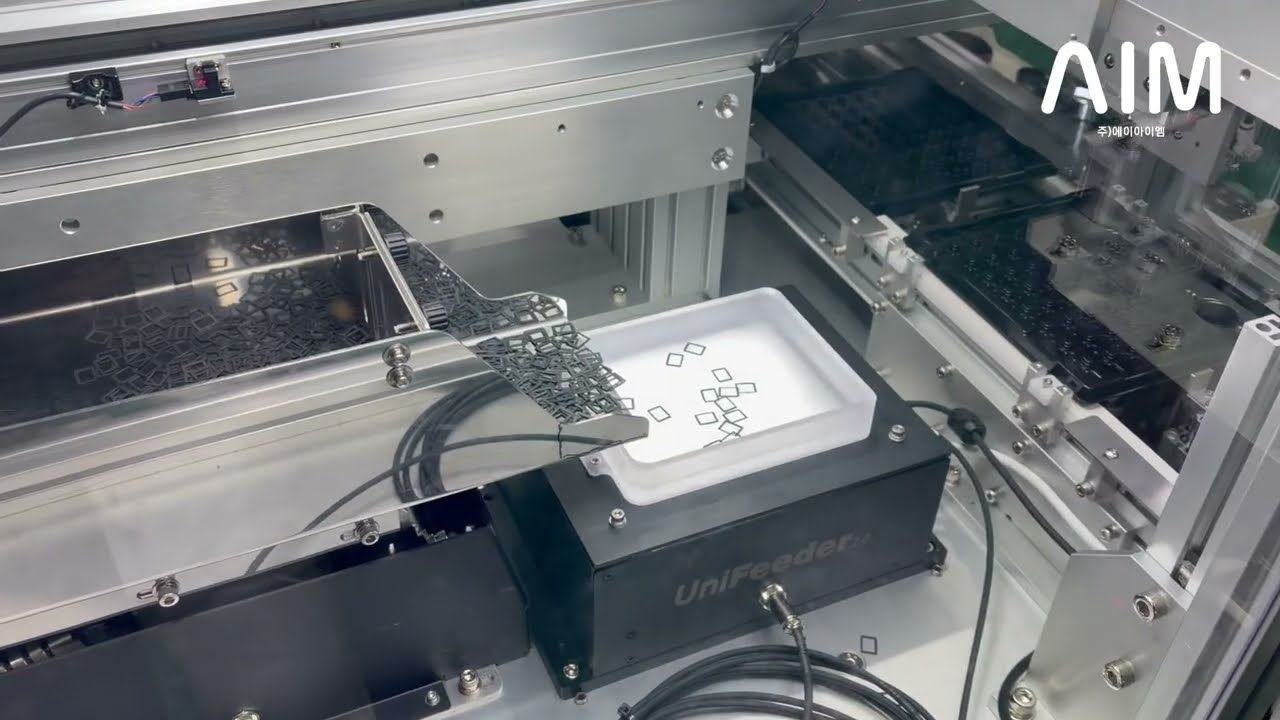
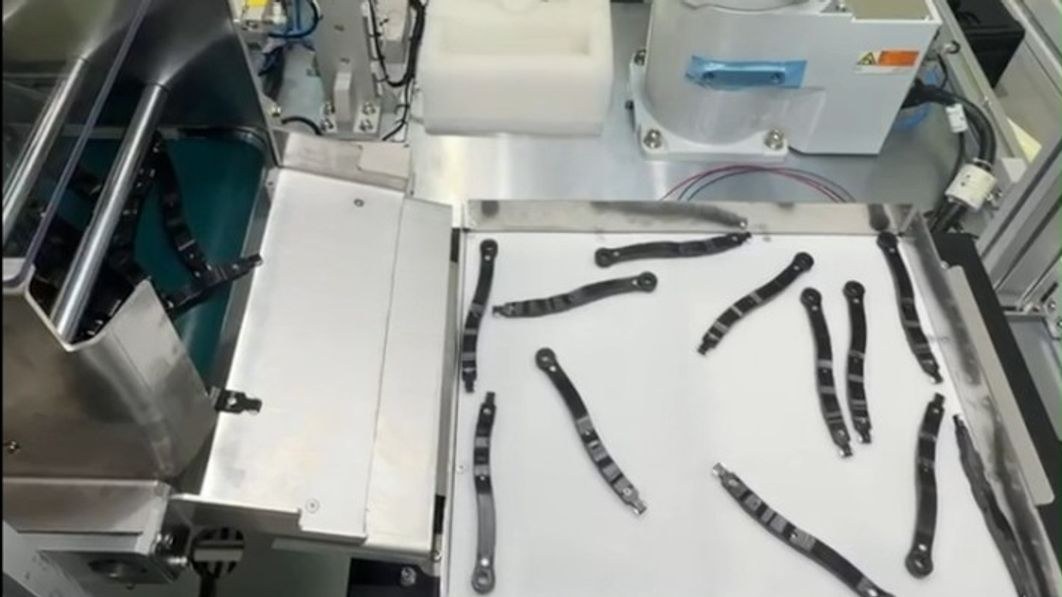
High-Speed Feeding of Plastic Injection-Molded Parts — One Part Every ~2 Seconds with a Cartesian Robot — part and detection view

Solution

While the feeder spreads and vision reads, the Cartesian robot picks and places one part every ~2 seconds

The UNI FEEDER flexible feeder, RoboEye machine vision and a Cartesian robot were integrated into a single flow. The feeder spreads the plastic injection-molded parts on the feed surface, vision recognizes the position and orientation of each part in real time, and the Cartesian robot performs high-speed pick-and-place at those coordinates. Because there is no assumption that parts are loaded in a predetermined pose, injection-molded parts of various shapes are handled with the same configuration.

  • Feeding — UNI FEEDER flexible feeder
  • Recognition — RoboEye machine vision (real-time position and orientation recognition)
  • Handling — Cartesian robot high-speed pick-and-place

Results

A cycle time of about 2 seconds while keeping the feeding method flexible

  • Pick-and-place cycle time of about 2 seconds — based on the plastic injection-molded parts shown in the video.
  • Plastic injection-molded parts of various shapes were fed stably with the same feeder.
  • Position and orientation are recognized in real time, and Cartesian robot pick coordinates are passed according to the pose each part lies in.
  • Configured on the premise of a production environment where items change.
  • Scope of disclosure — the public material for this case is a 1-minute-11-second video of the system in operation.
FAQ

Frequently asked about this case

Doesn't a flexible feeder slow down an injection-molding line?

In this case, pick-and-place ran at a cycle time of about 2 seconds while feeding with UNI FEEDER. That figure is for the plastic injection-molded parts shown in the video, and it varies with part shape and process configuration.

Can machine vision coordinates be passed to a Cartesian robot?

The robot in this case is a Cartesian robot. RoboEye machine vision passes the recognized position and orientation of each part to the robot in real time to set the pick point.

Can injection-molded parts of different shapes be fed with the same feeder?

This configuration was built on the premise of feeding plastic injection-molded parts of various shapes with the same feeder. There is no need to pre-align the parts in a fixed pose.

How much has been disclosed about this case?

The public material is a 1-minute-11-second video of the system in operation. Apart from the cycle time of about 2 seconds, no measurements such as pick success rate or alignment error have been disclosed. The customer's name is not disclosed either.