Case Study · Electronic component manufacturing

Micro Electronic Component Reel Taping with a FANUC Robot — Feeding, Picking and Inspection in One Flow

The AIVE flexible feeder spreads micro electronic components evenly, 2D robot vision recognizes their position and orientation and passes coordinates to a FANUC robot, and picking, reel taping and inspection follow in a single cell.

Electronic Component Pick & Place | Flexible Feeder + 2D Robot Vision Automation

Watch on YouTube →

What and how

Configuration of this case

Part
Micro electronic components
Process
Flexible feeder → 2D vision position/orientation recognition → robot pick → reel taping → inspection
Robot
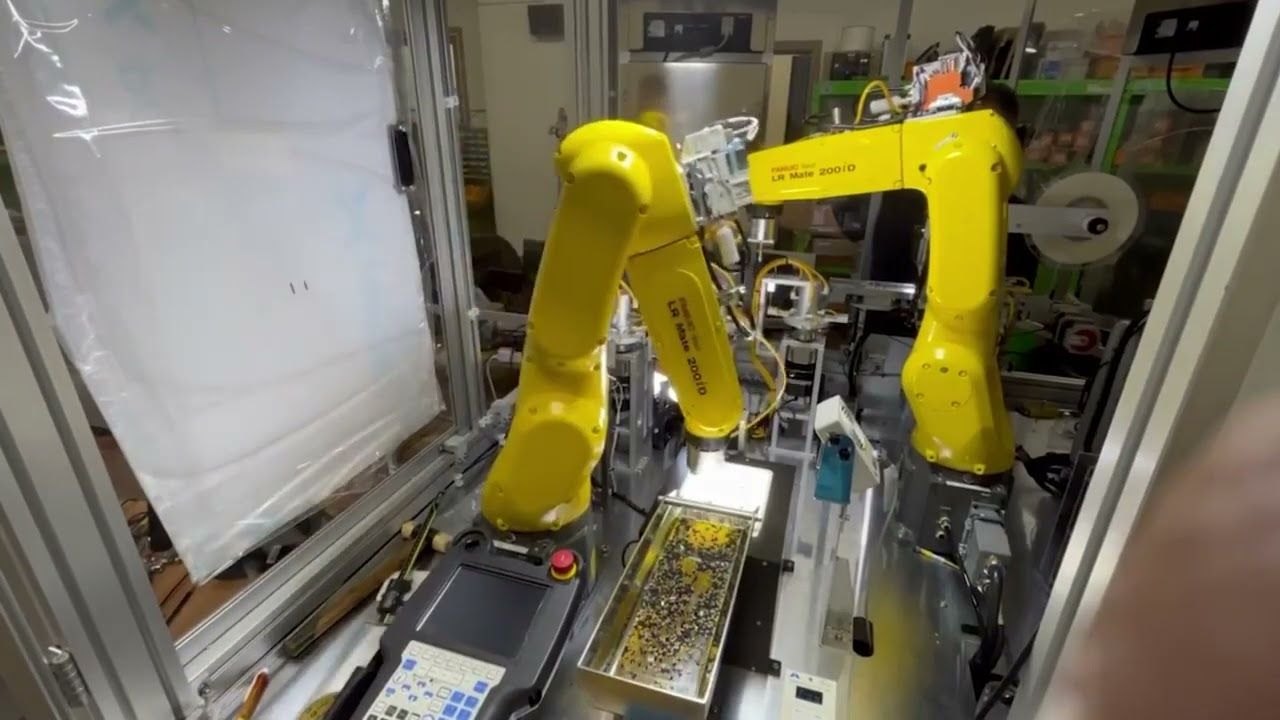
FANUC LR Mate 200iD
Feeder · Vision
AIVE flexible feeder + 2D robot vision
Industry
Electronic component manufacturing
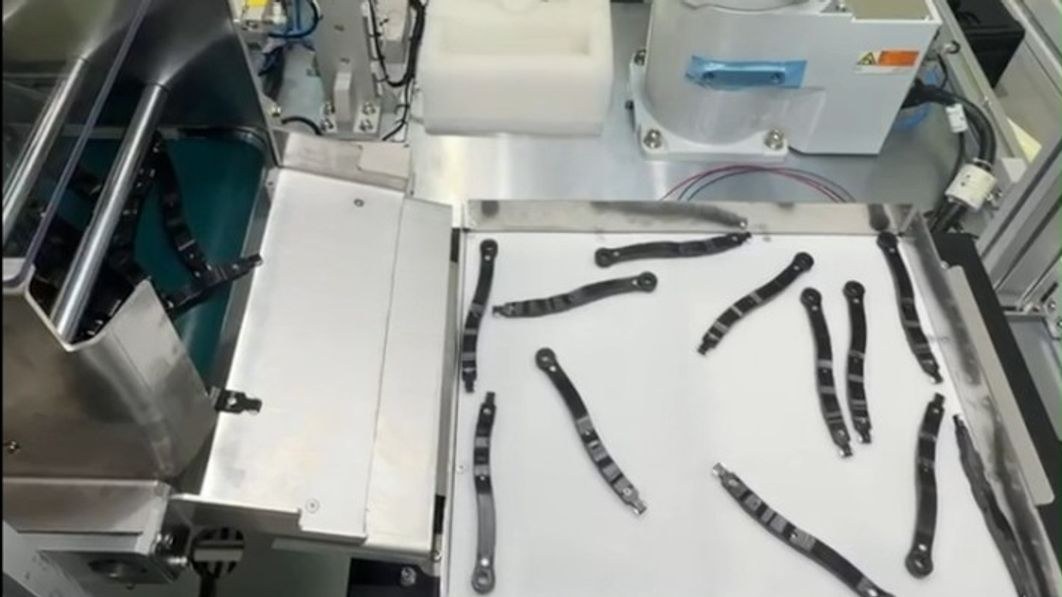
Micro Electronic Component Reel Taping with a FANUC Robot — Feeding, Picking and Inspection in One Flow — part and detection view

Solution

The feeder scatters the parts, 2D vision reads position and orientation, and the FANUC robot picks and places them on the reel

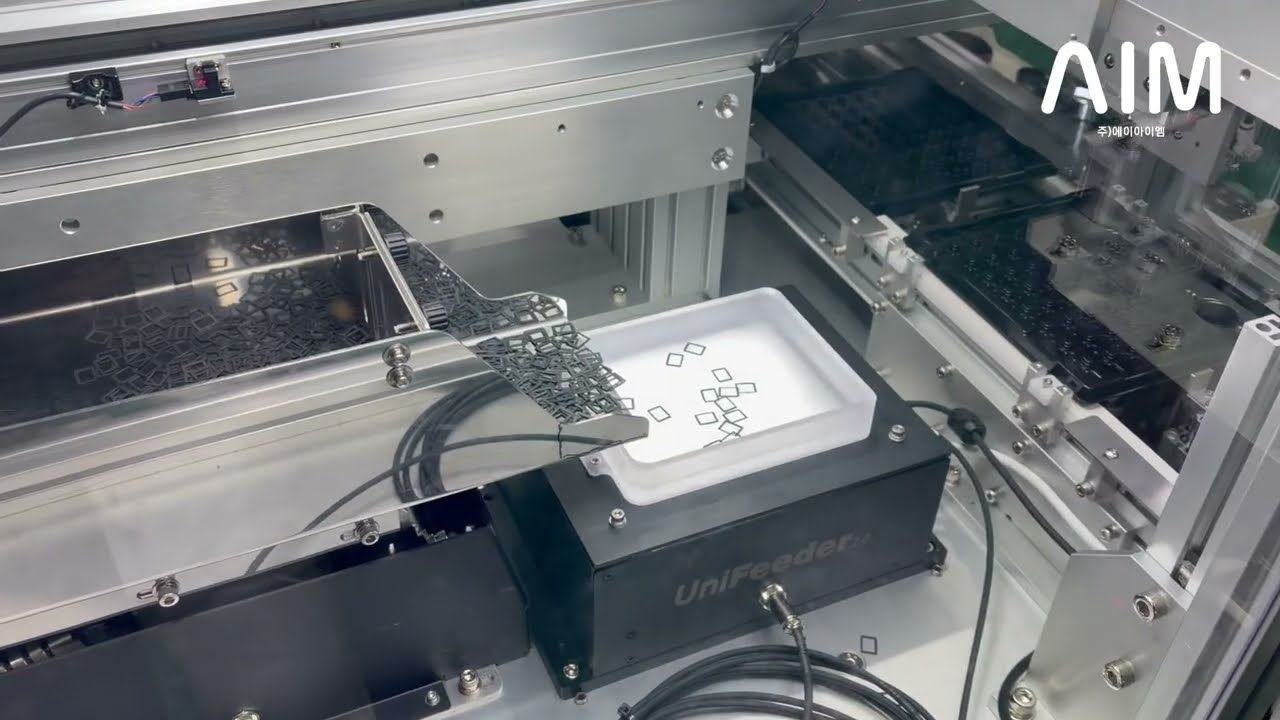
The AIVE flexible feeder spreads the micro electronic components evenly. 2D robot vision recognizes the position and orientation of the spread parts and passes coordinates to the FANUC robot, which picks at those coordinates and tapes the part onto the reel. Feeding, recognition, picking, reel taping and inspection all follow one another inside a single cell.

  • Micro part feeding — the AIVE flexible feeder spreads the parts evenly.
  • 2D vision recognition — detects the position of the spread parts.
  • Orientation judgment — reads the orientation in which each part lies as well.
  • Pick · reel taping — the FANUC robot picks at the received coordinates and places the part on the reel.
  • Inspection — the inspection process follows inside the same cell.

Results

Micro electronic components go from feeding to reel taping and inspection with no hands in between

  • Part feeding, vision recognition, robot picking, reel taping and inspection were tied into a single automated flow.
  • Position and orientation are recognized together, so parts are picked according to the pose they lie in.
  • Coordinates generated by vision are passed to the FANUC robot to secure pick accuracy.
  • Reel taping is performed with a configuration that feeds micro electronic components stably.
FAQ

Frequently asked about this case

Can vision and a flexible feeder be integrated with a FANUC robot?

This case was built with a FANUC robot. The coordinates produced by 2D robot vision are passed to the robot for picking and reel taping. FANUC is integrated through its vendor-specific protocol, and the implementation record is documented in a separate research note.

Is the reel taping done in the same cell?

In this case, flexible feeding, 2D vision recognition, robot picking, reel taping and inspection run as one continuous flow. There is no step where parts are transferred to another container or fed in by hand along the way.

Is the inspection of the taped result done by the same system?

This case includes an inspection process. Inspection items and pass/fail criteria differ by part and line, though, so verification against the target part is needed.

How do you feed micro parts that are difficult for a vibratory feeder?

In this case, the AIVE flexible feeder spreads the micro electronic components evenly. 2D robot vision then recognizes the position and orientation of the spread parts and passes them to the robot.

Can 2D vision recognize the position and orientation of micro electronic components?

In this case, 2D robot vision recognizes both the position and the orientation of the parts. It reads the pose in which each part lies and generates the pick coordinates for the robot.

Can the same configuration handle other micro parts?

This case was configured specifically for handling micro parts. Feeder and vision conditions depend on the shape and size of the part, so verification against the target part is needed.