Research Note 08
Real-time 3D vision tracking — following a moving part with a robot-mounted camera
A demo record: one 3D camera on the robot arm tracks the position and orientation of a moving part, and the robot is controlled directly from outside.
- Robot-mounted 3D camera (eye-in-hand)
- Real-time position and orientation tracking
- Camera–robot time sync
- Direct external control
- Hyundai robot
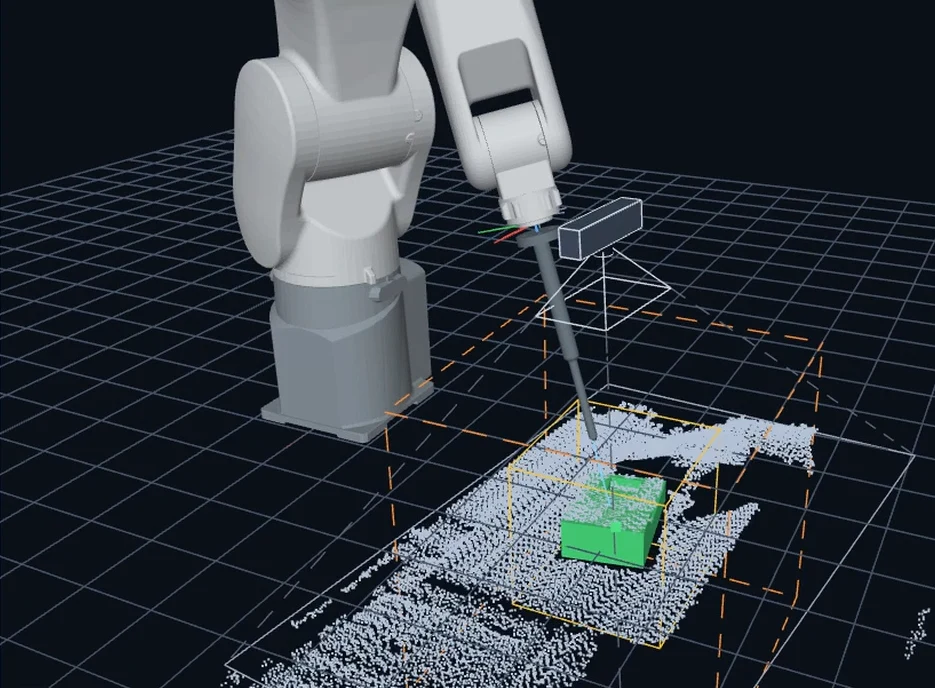
The robot follows a moving part in real time. One 3D camera is mounted on a Hyundai robot arm. It tracks the position and orientation of the part, and our software controls the robot directly from outside. The video is recorded at real speed.
The camera is not fixed — it moves with the robot (eye-in-hand). Camera and robot data are time-synced for stable tracking. One 3D camera is used, with no conveyor encoder.
There is no robot script on the robot side; control comes directly from outside. Reference registration and tracking setup are done in one software.
This is a record from before it became a product
What this note describes is not a feature of the products we sell today. If you are considering it for an application, tell us the target and the conditions.